SHAFT: A Slack-Compensating, Helical-Buckling-Attenuating Flexible-Shaft Transmission for Lightweight Multi-DoF Manipulation
IROS2026
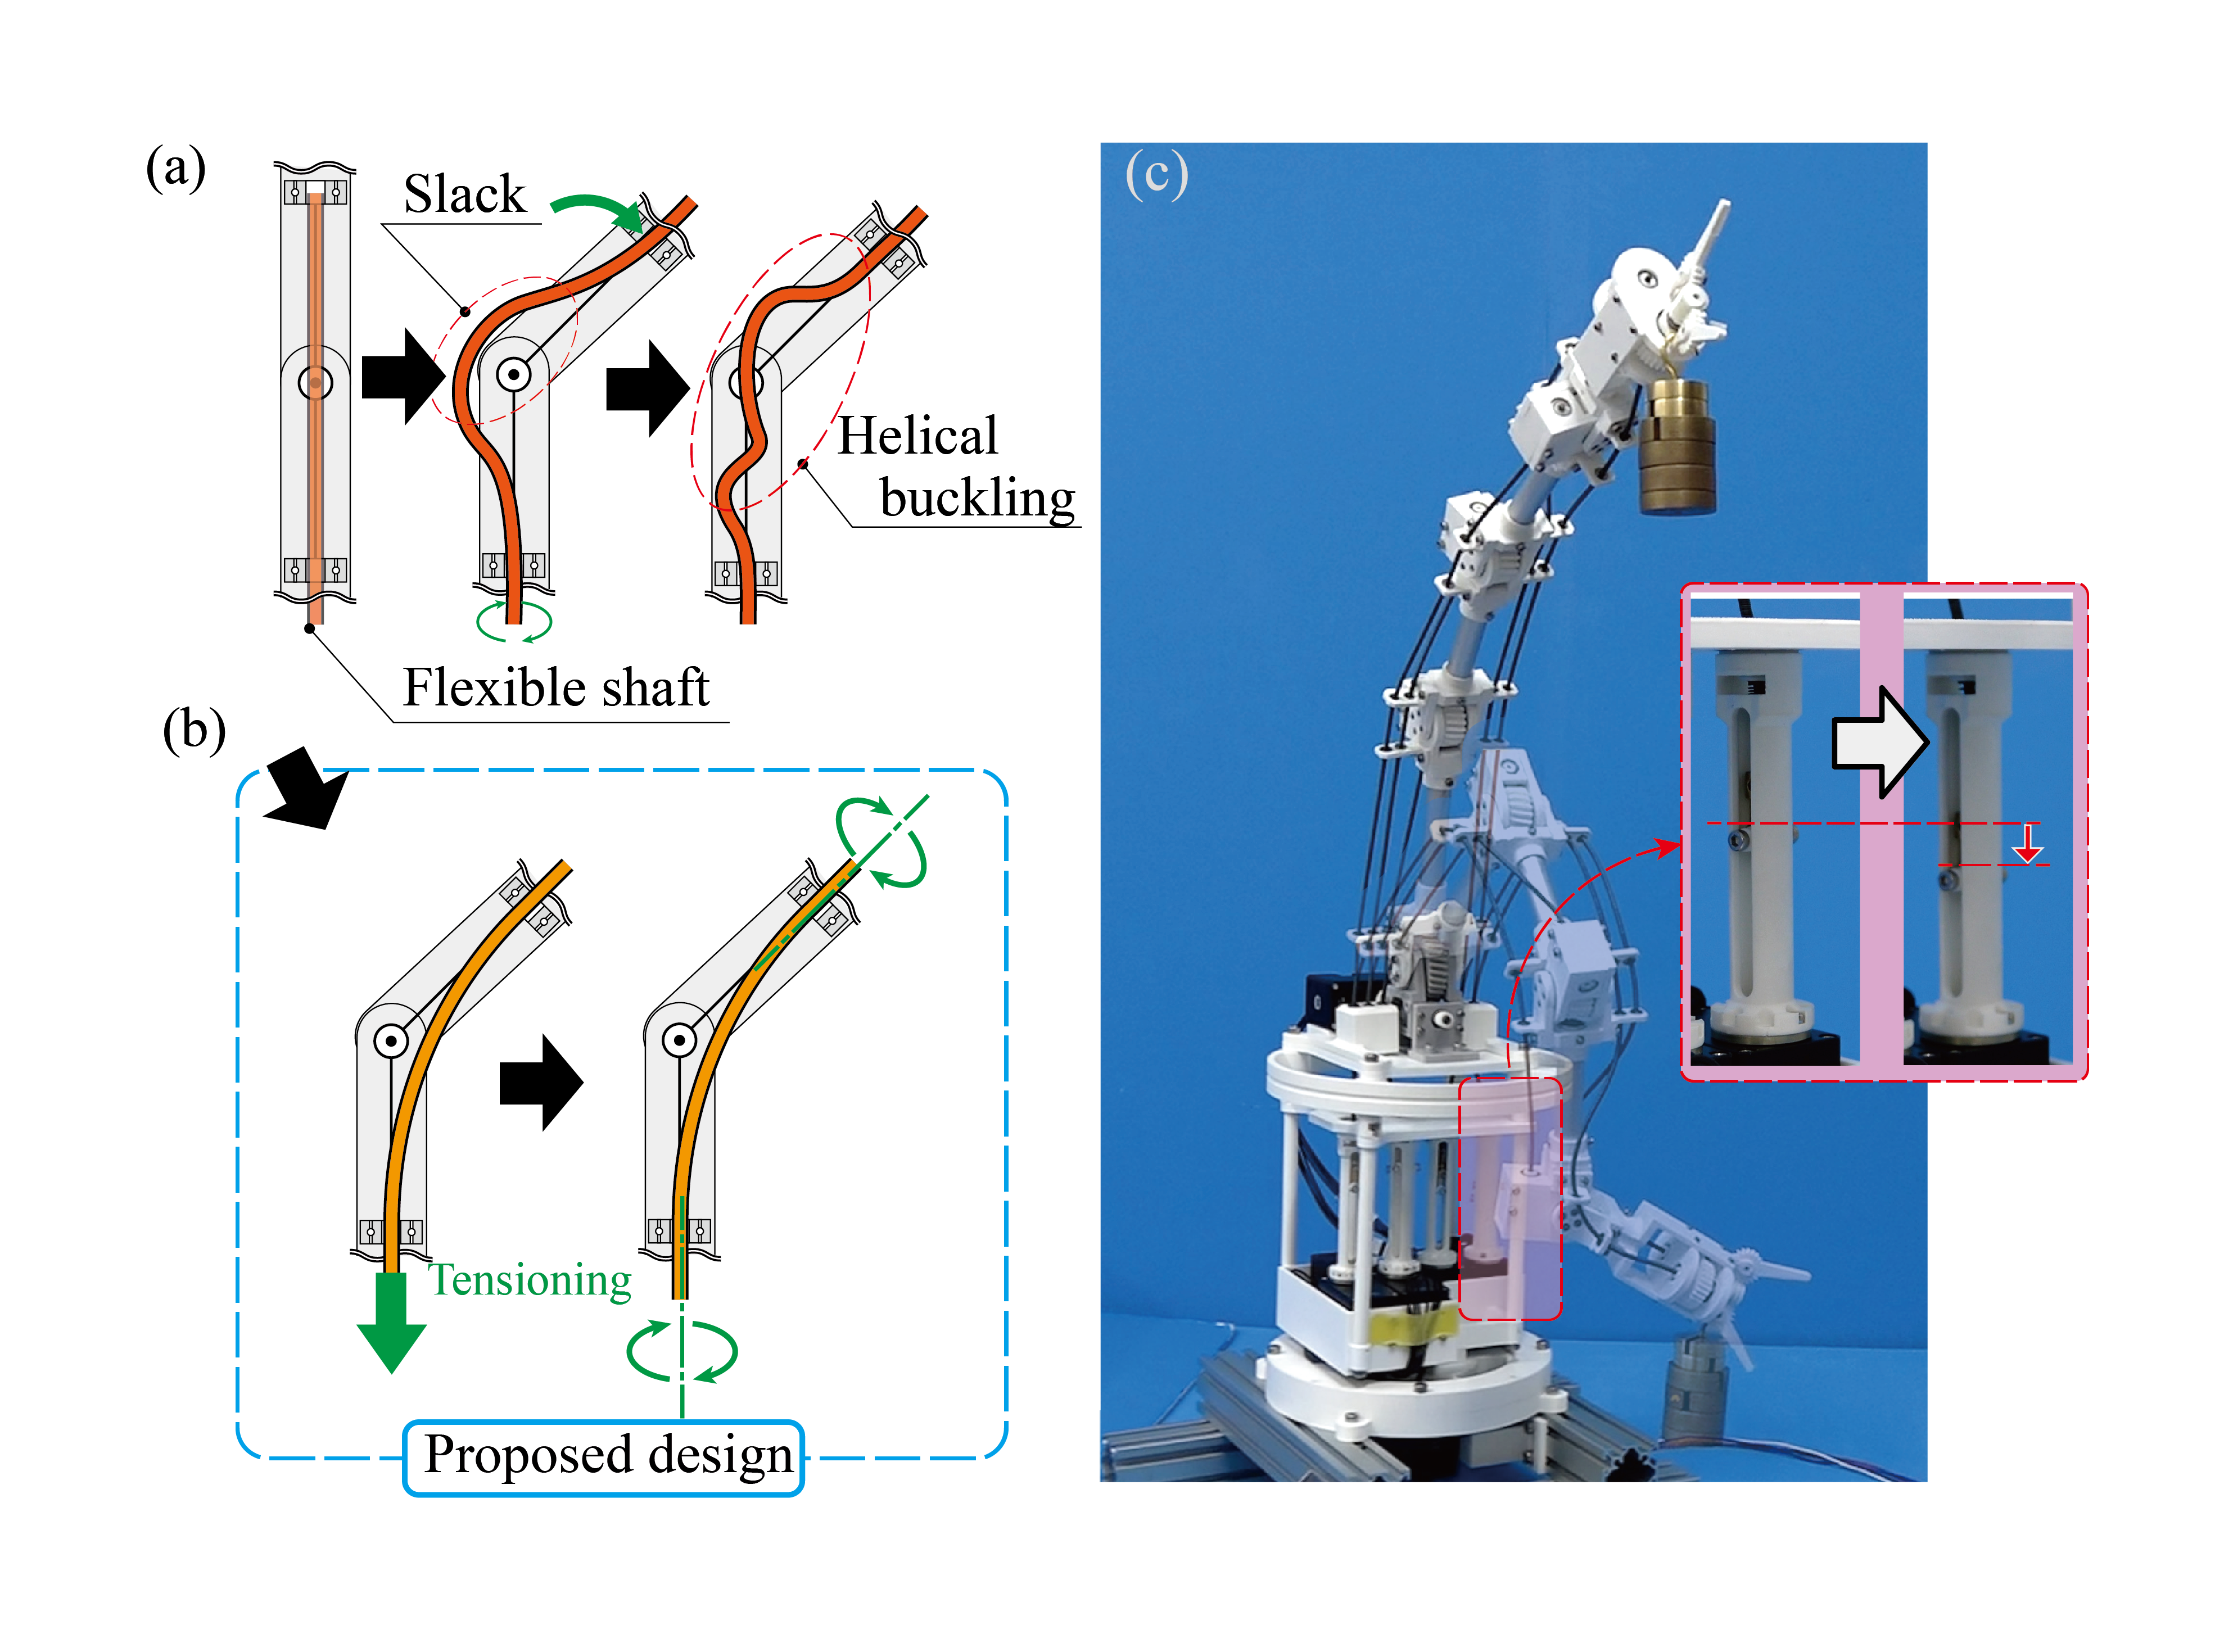
TL;DR This study proposes SHAFT, a flexible-shaft transmission mechanism that compensates for slack with a proximal tensioner to suppress helical buckling in lightweight, remotely actuated manipulators. Compared with a flexible shaft without a tensioner, SHAFT improves transmission efficiency by about 30% and reduces angular transmission error by about 65% on a path with four 90-degree bends. Using SHAFT, we built a 6-DoF arm with a 1-DoF gripper whose arm module weighs only 280 g.
Overview
Slim, lightweight manipulators are key to operating safely around people. Placing motors near the base and sending torque to distal joints through remote transmissions (e.g., wires or Bowden cables) lowers arm inertia and size, but existing designs either add mass (pulleys for redirection) or lose efficiency to friction. Flexible-shaft transmission avoids both issues, yet slack that appears when joints bend causes helical buckling and growing angular transmission error. We propose SHAFT, a Slack-compensating, Helical-buckling-Attenuating Flexible-shaft Transmission that removes this slack with a tensioner located at the proximal side, so the moving mass of the arm does not increase. On a transmission path with four 90-degree bends, SHAFT achieved roughly 30% higher efficiency and roughly 65% lower angular transmission error than a flexible shaft without a tensioner. We also built a 6-DoF arm with a 1-DoF gripper, composed of a rotary module that houses the motors and tensioner and an arm module weighing 280 g. This remote actuation approach offers a lightweight, efficient path toward deploying safe robots in human environments.
Video
Contact
Citation
# arXiv version
@article{takahashi2026shaft,
    title={SHAFT: A Slack-Compensating, Helical-Buckling-Attenuating Flexible-Shaft Transmission for Lightweight Multi-DoF Manipulation},
    author={Takahashi, Tomoya and Selvamuthu, Moses Gladson and Tadakuma, Richiro and Tanaka, Kazutoshi},
    journal={arXiv preprint arXiv:2609.22677},
    year={2026}
}