 THEME · Physical AI
Hardware
Hands, wrists, actuators and arms designed in-house — mechanisms that make contact-rich manipulation safe, compliant and cheap to build.
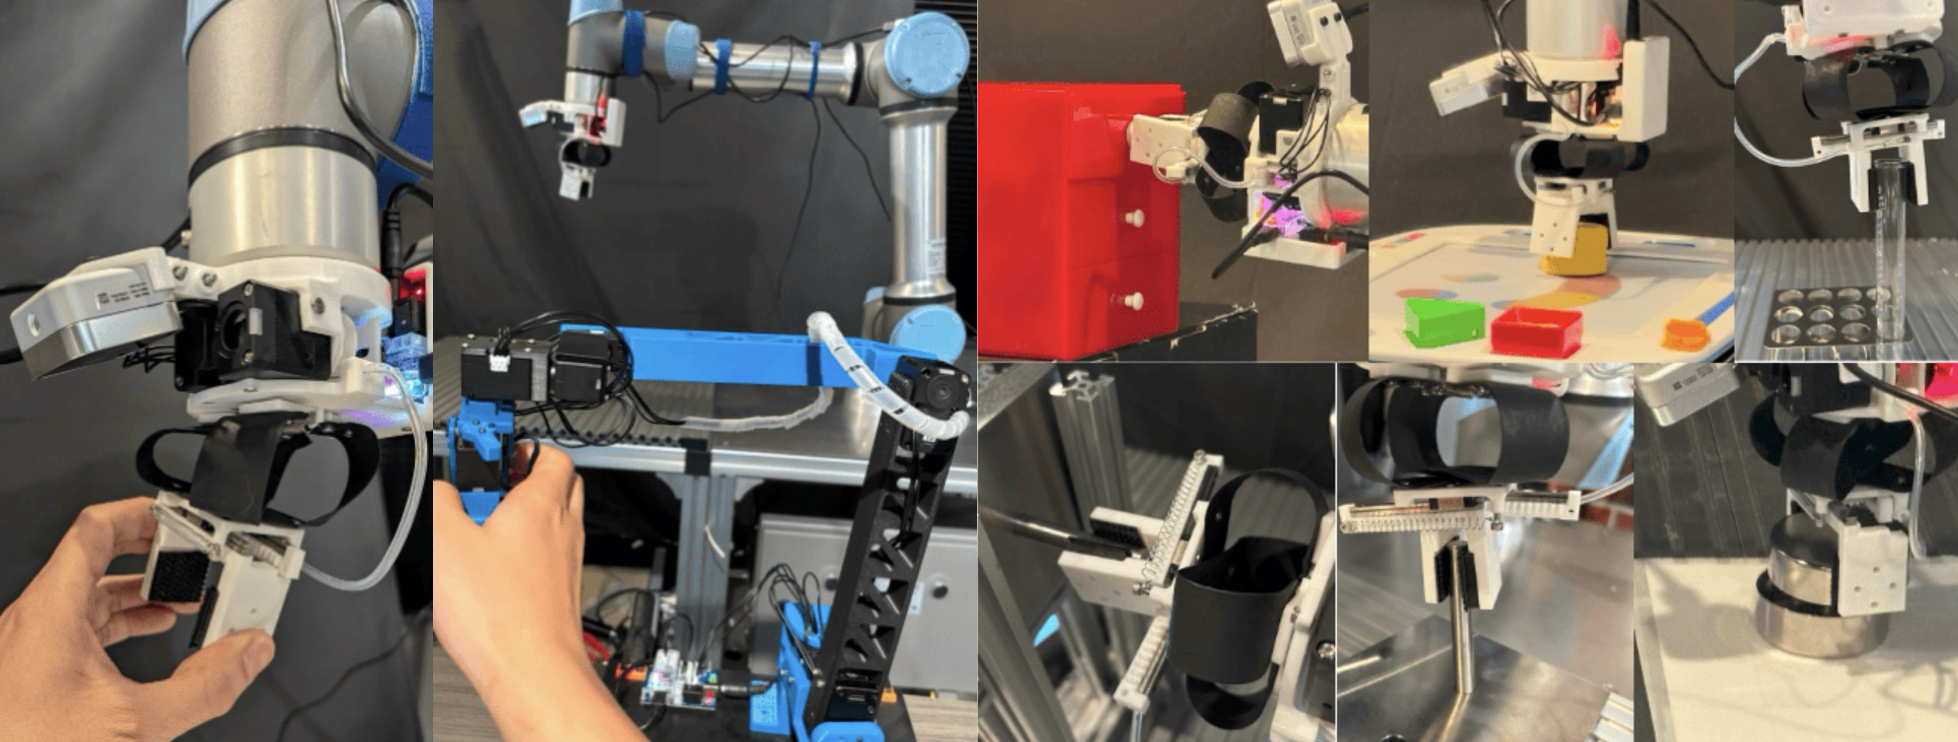
8 projectsA Flexible Wrist with Anisotropic and Switchable Stiffness for Contact-Rich Manipulation
Soft Conical Universal Robotic Hand for Scooping Granular Media from Containers of Various Sizes
Lightweight Four-Motor Prosthetic Hand Enabling Precision–Lateral Dexterous Manipulation
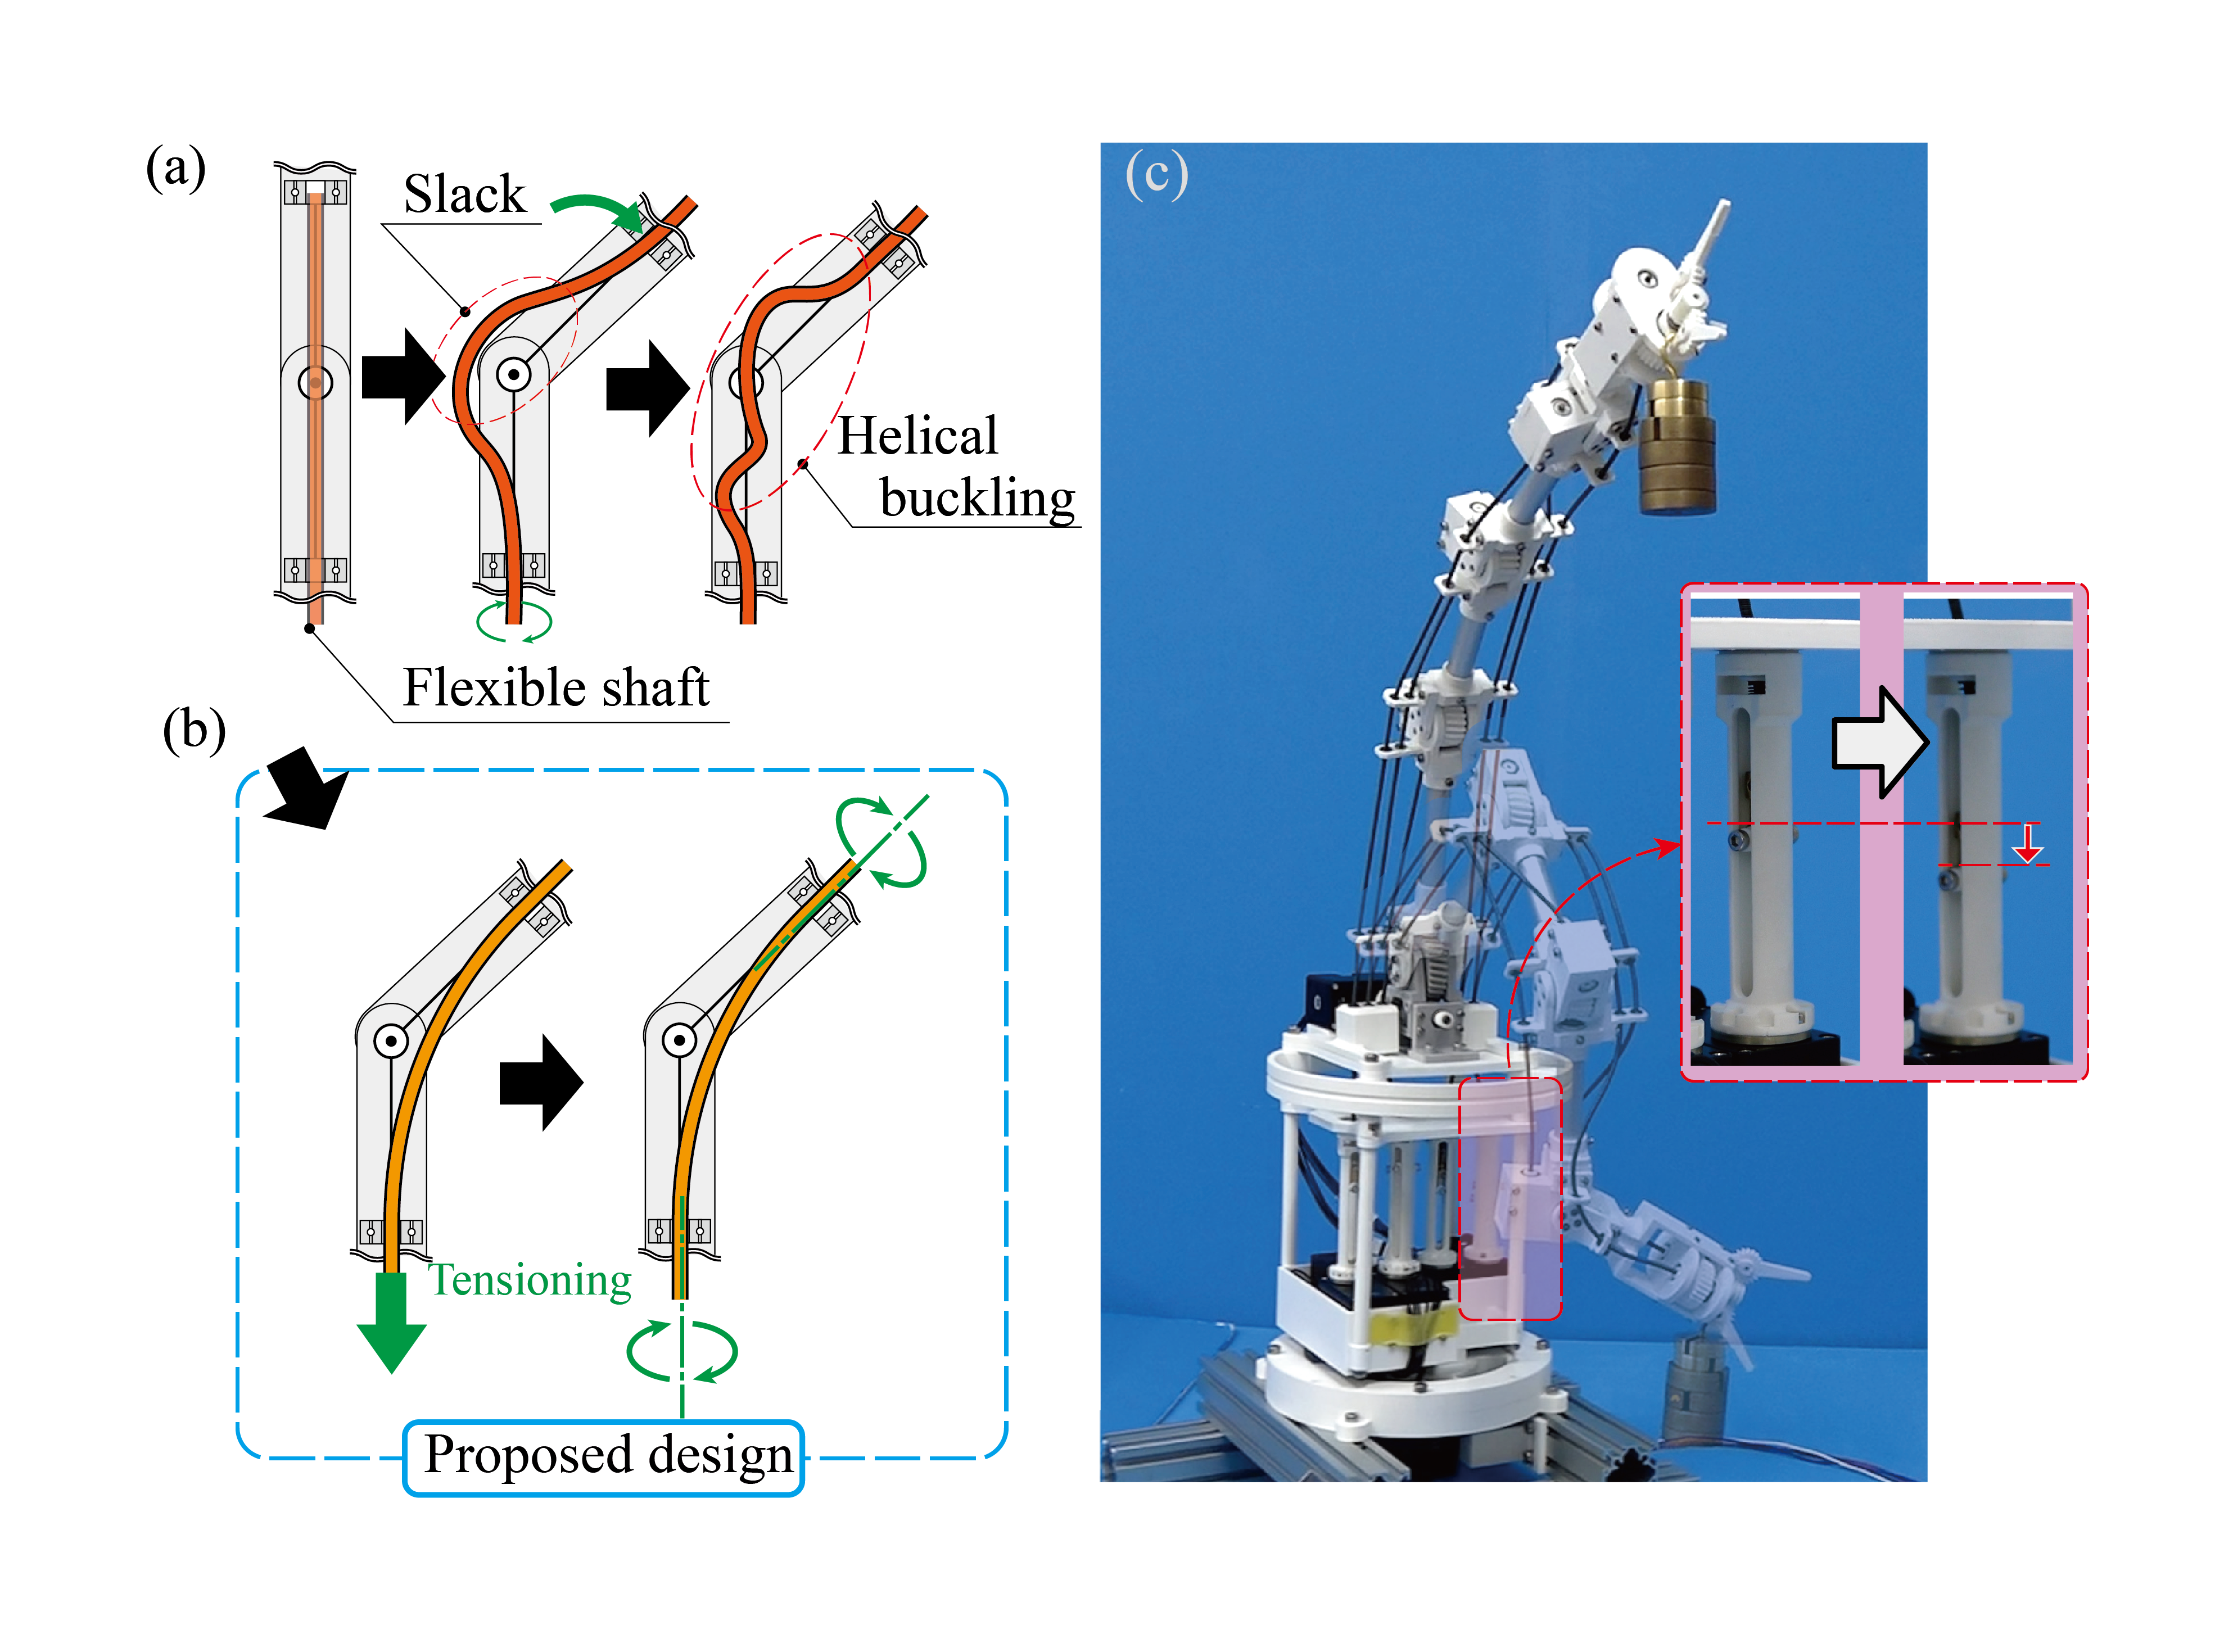
Worm Gear-based Adaptive Variable Elasticity for Decoupling Actuators from External Forces
a miniature-sized wheeled robot for swarm robotics research
Low-Cost Air Hockey Robot Using a Five-Bar Linkage Mechanism Driven by Position-Control Servomotors
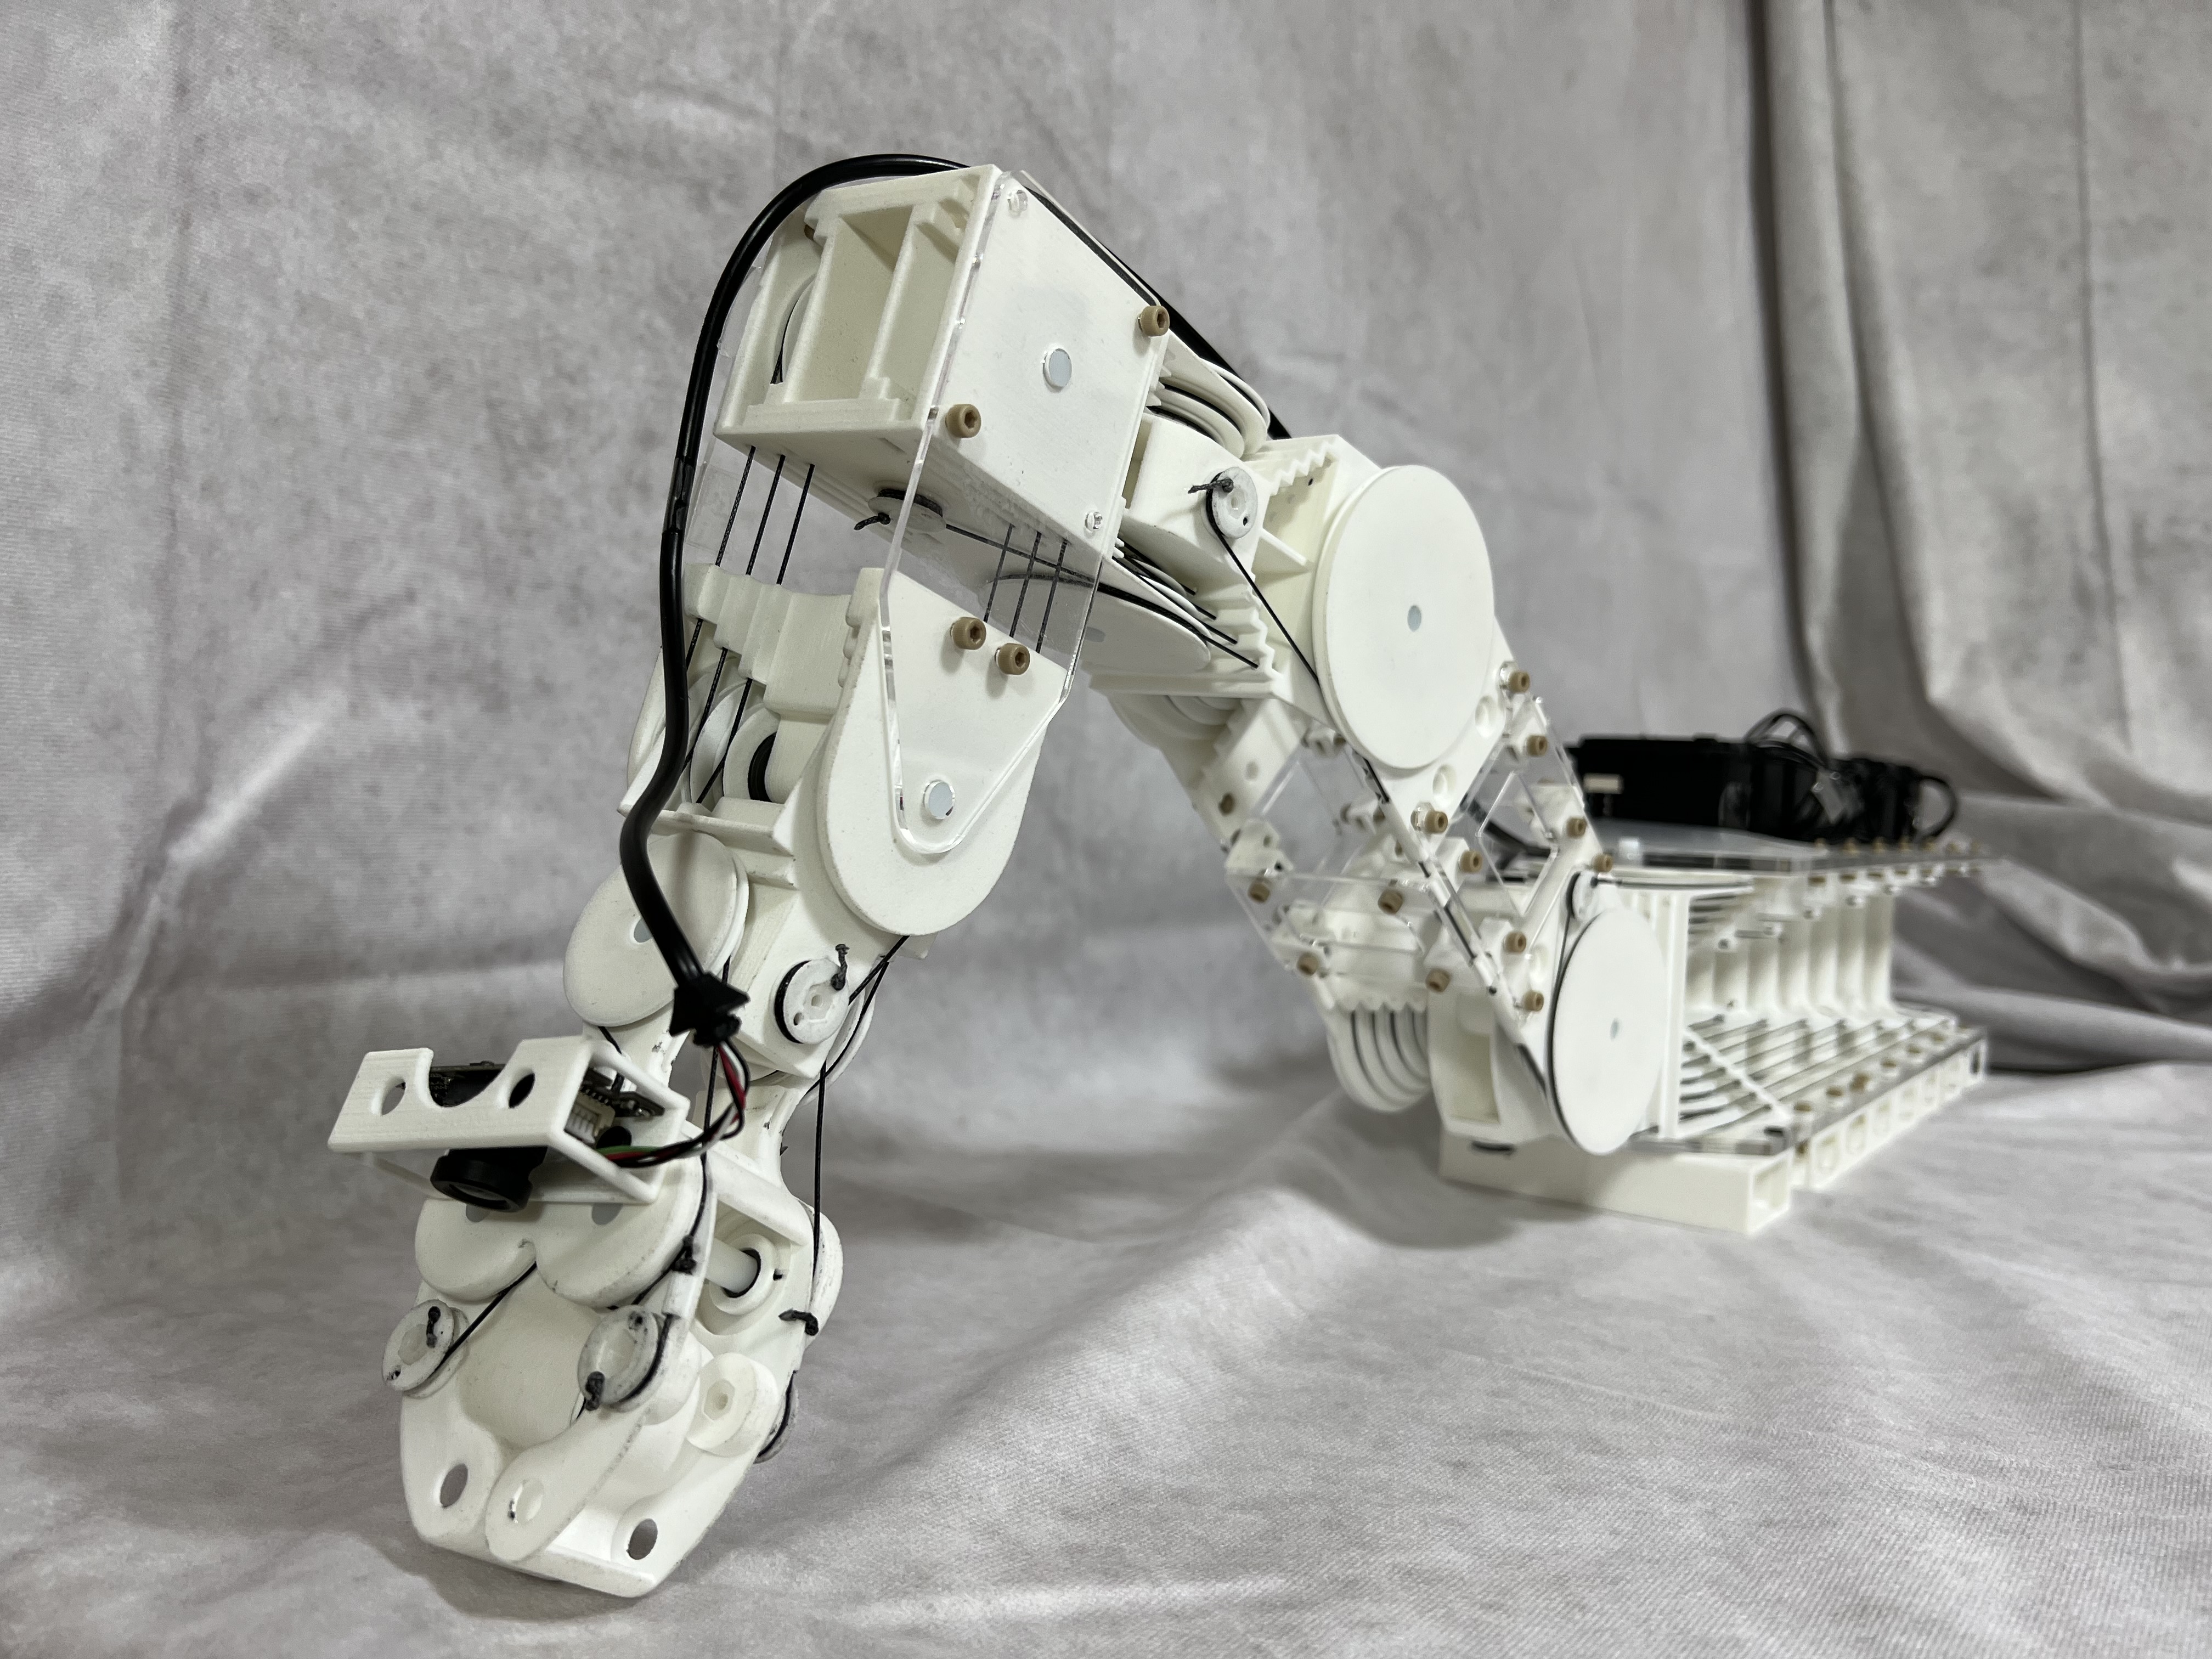
Plastic table-top cable-driven robotic arm with all motors located at the base link