 THEME · Physical AI
Soft Robotics
Soft wrists, compliant control and variable stiffness — letting robots touch, fit and insert safely by giving way instead of fighting contact.
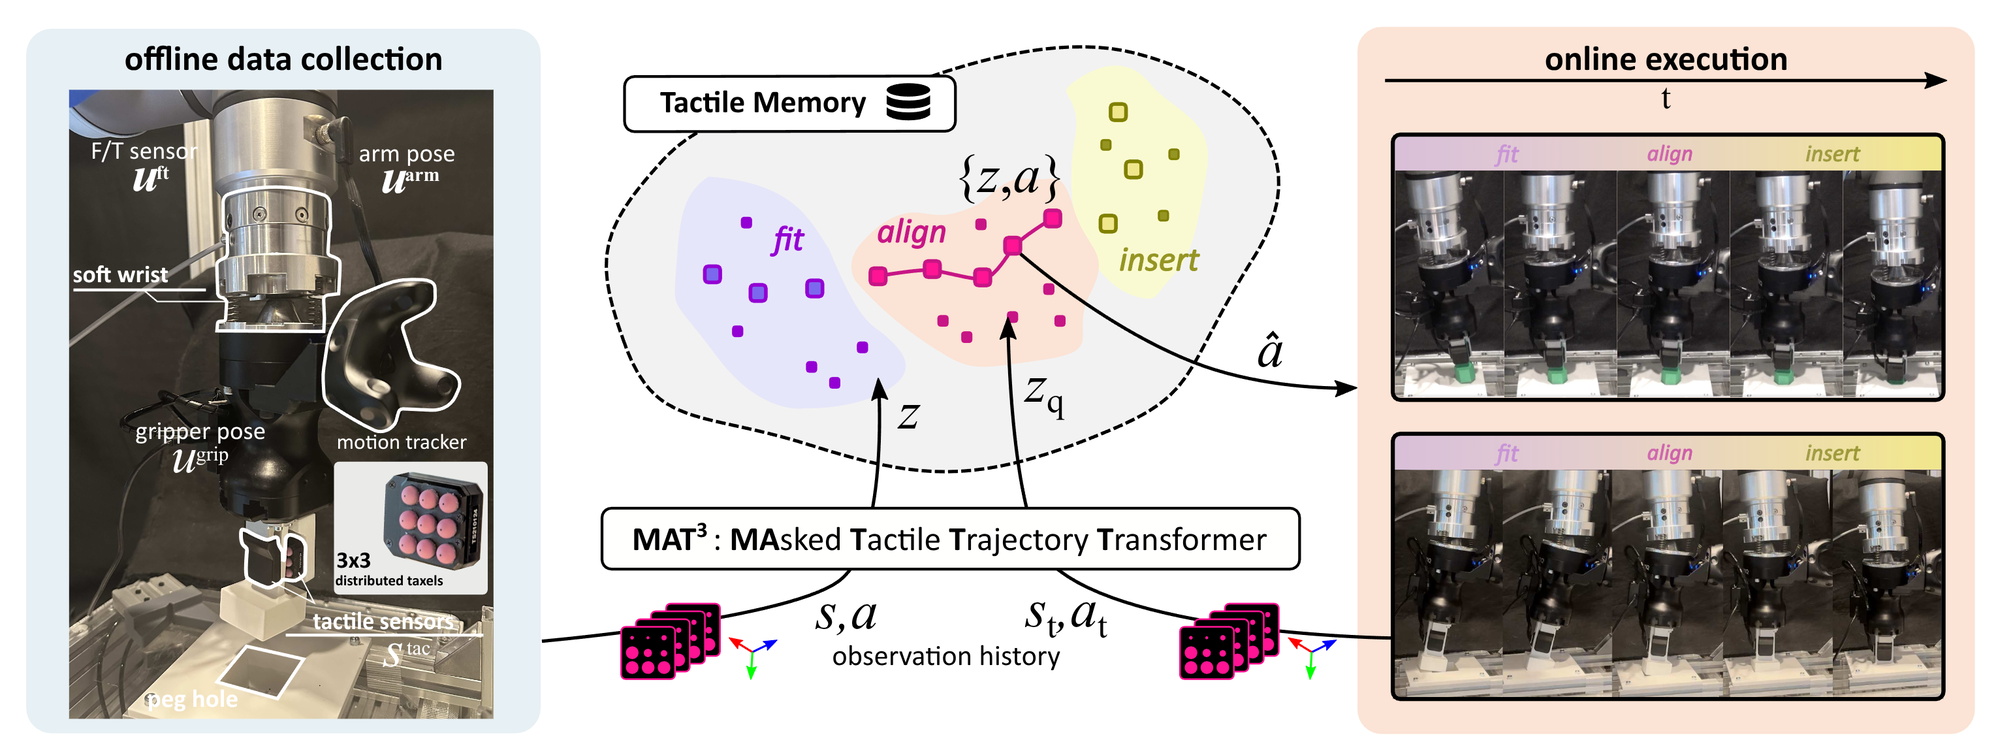
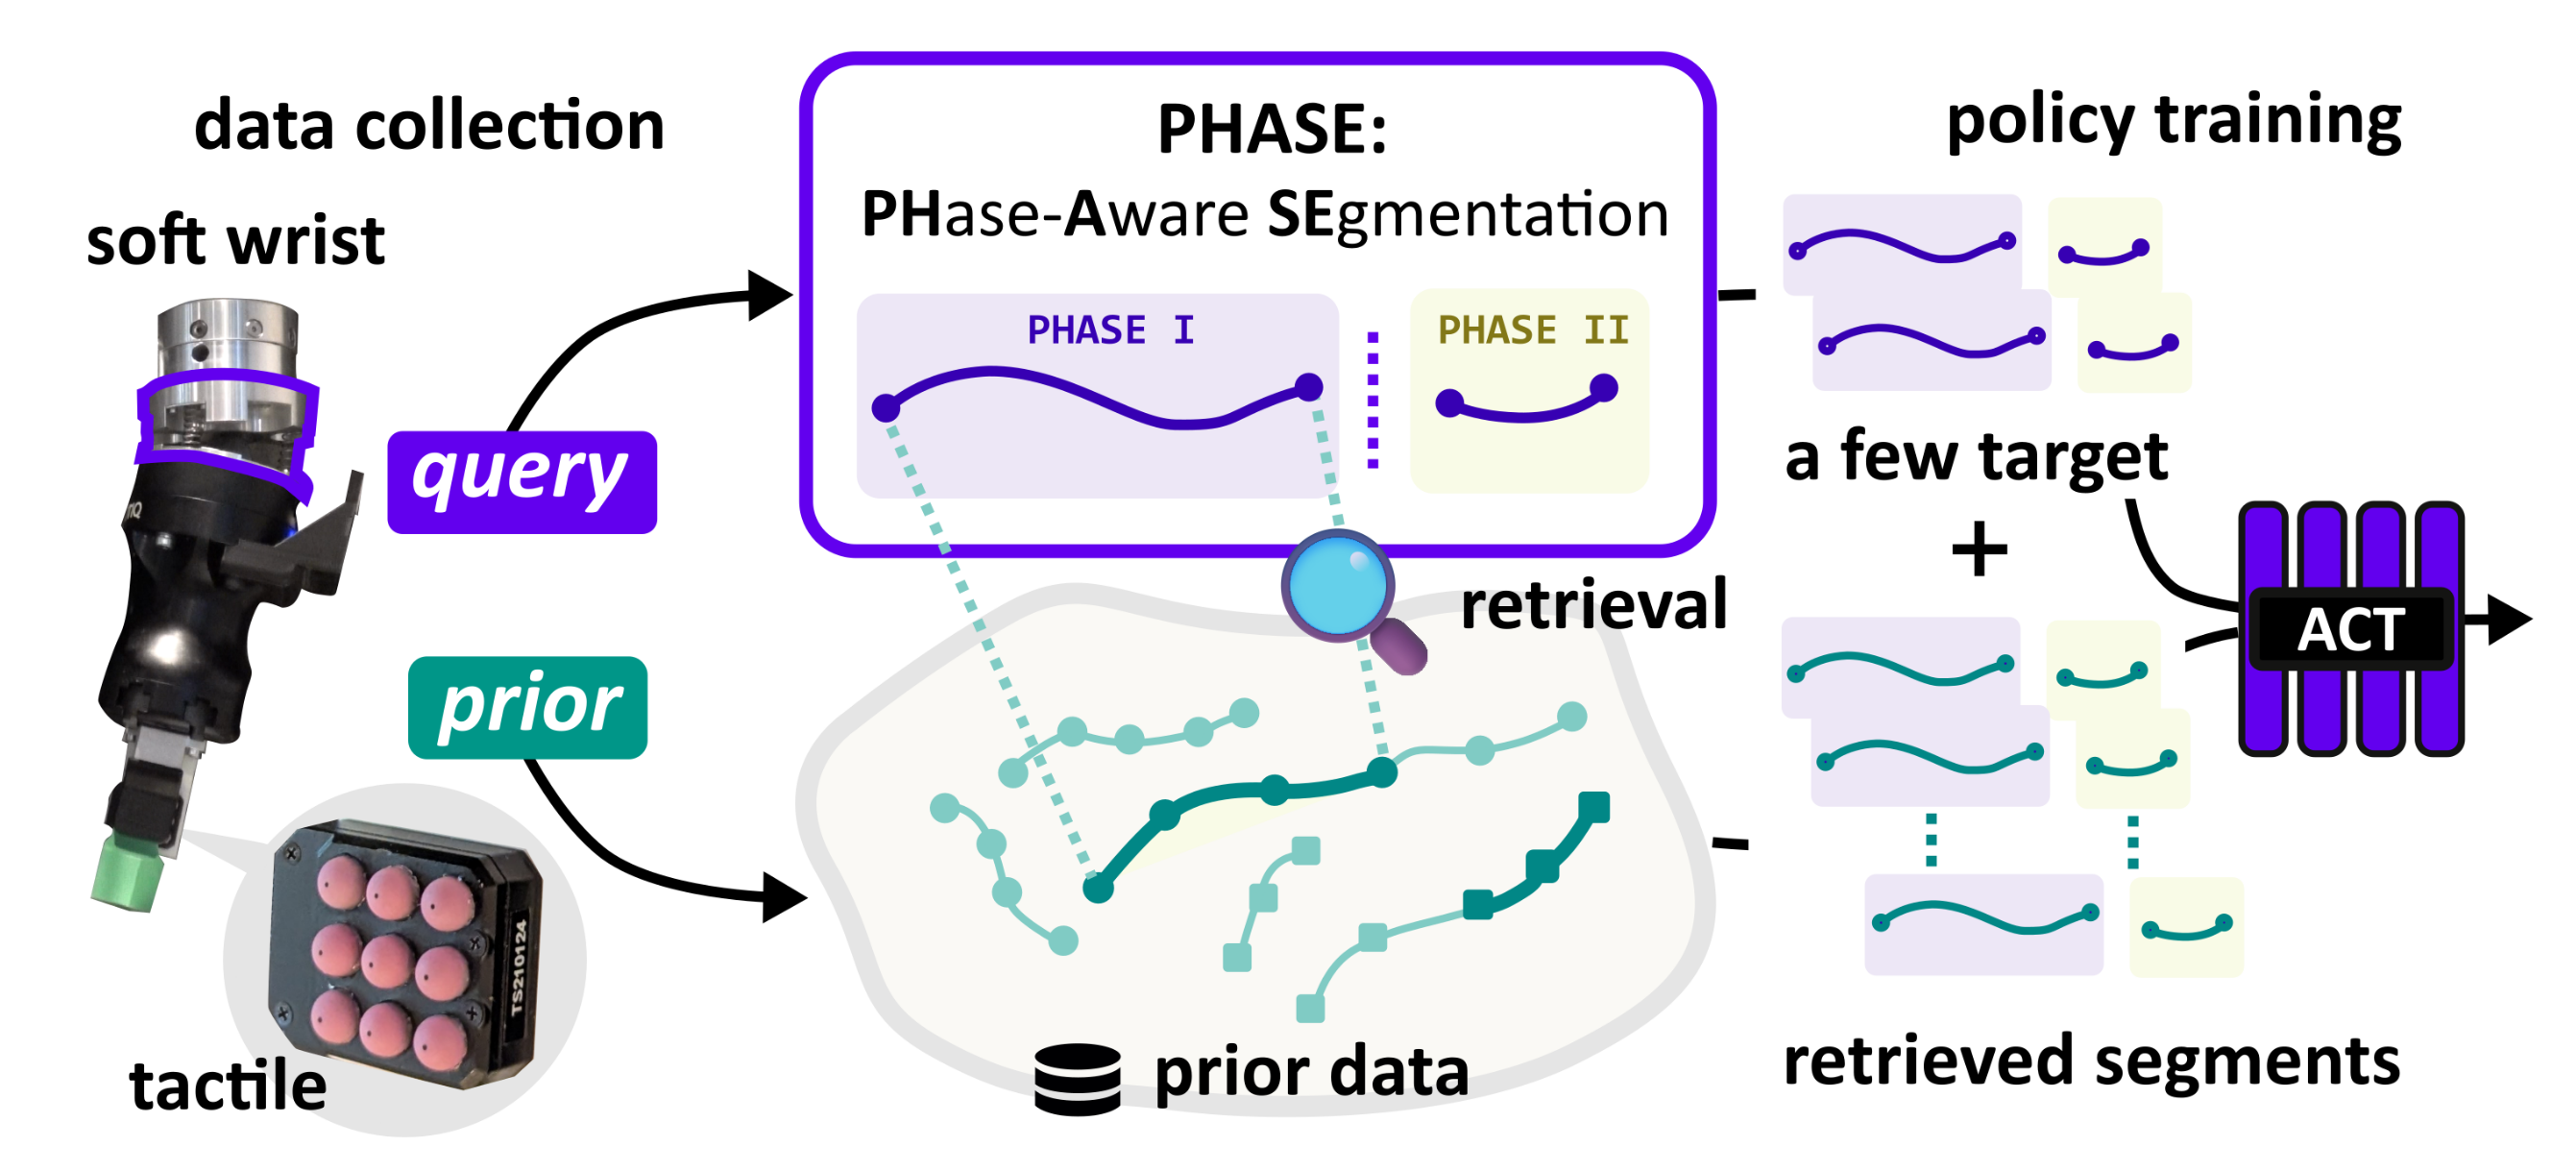
9 projectsCompliance-Enabled Tactile Phase Retrieval for Few-Shot Insertion Learning
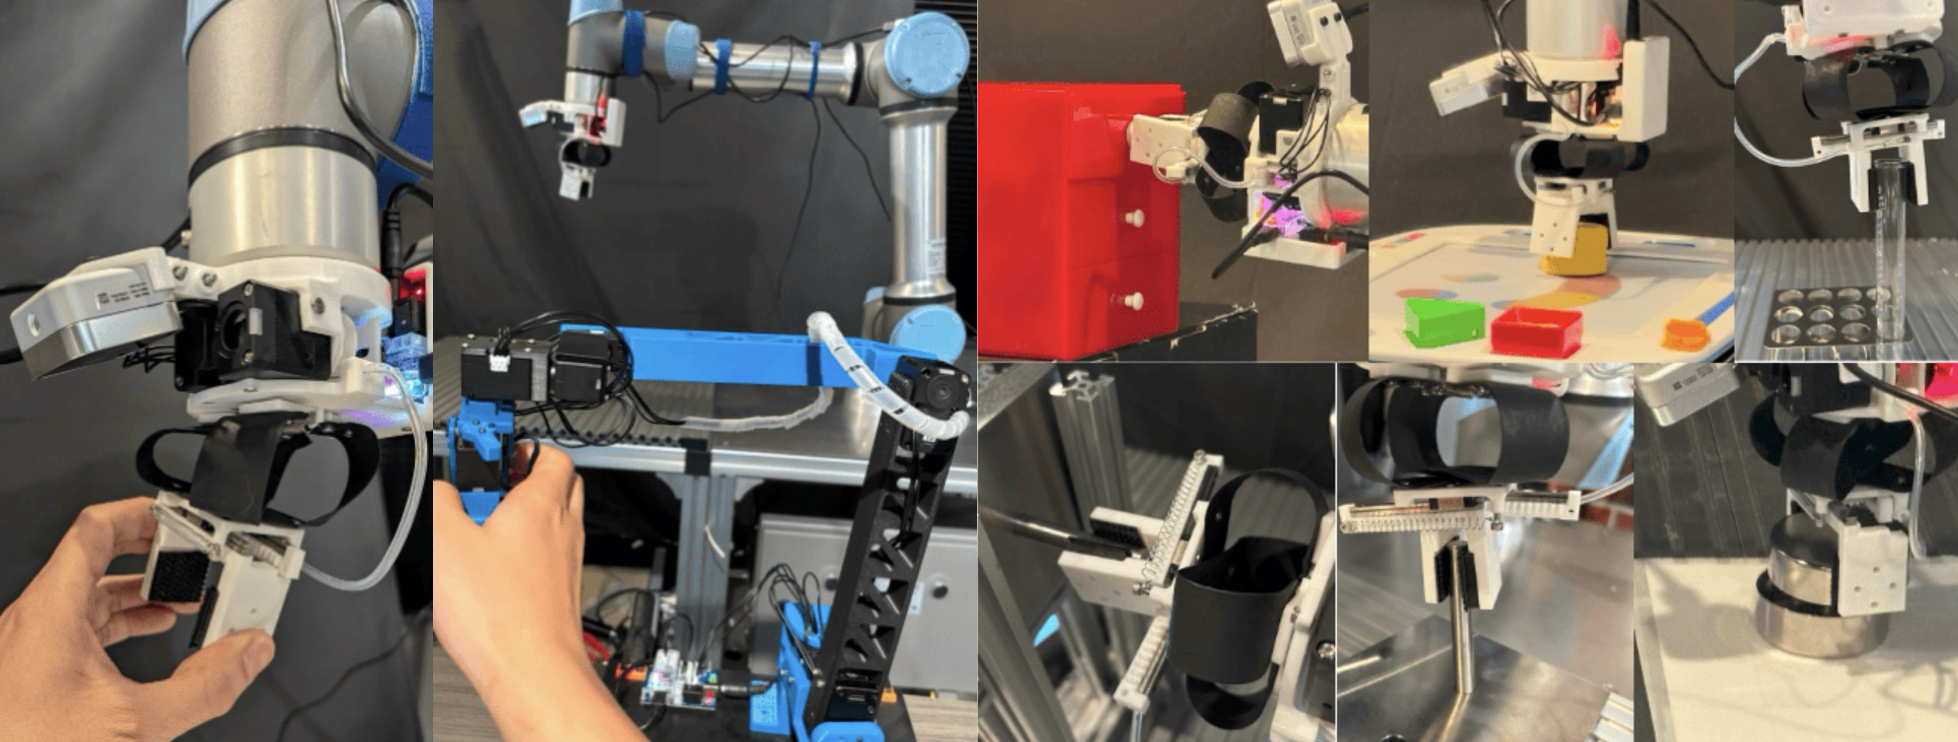
A Flexible Wrist with Anisotropic and Switchable Stiffness for Contact-Rich Manipulation
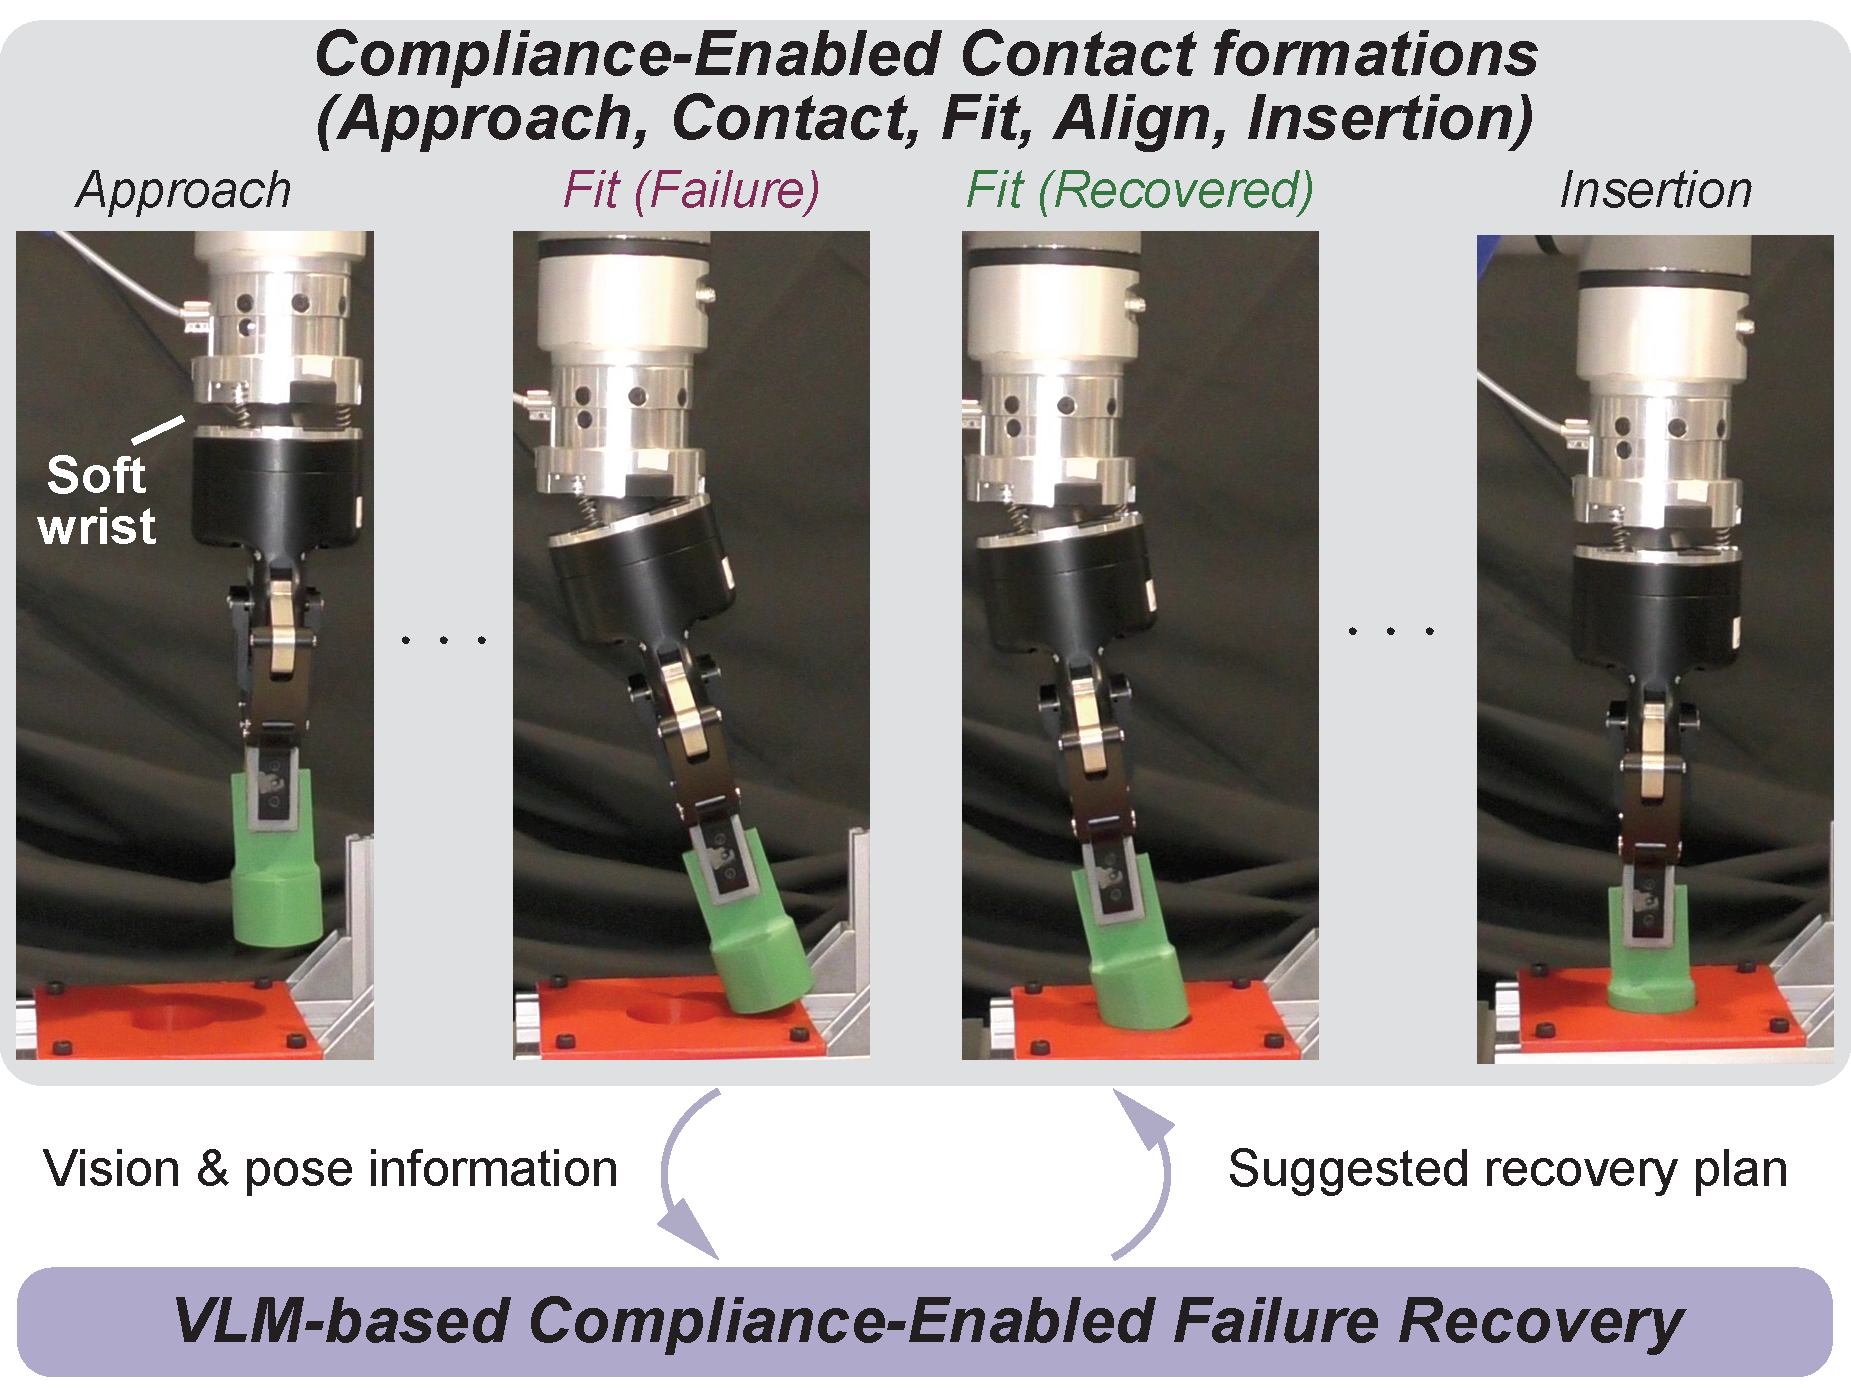
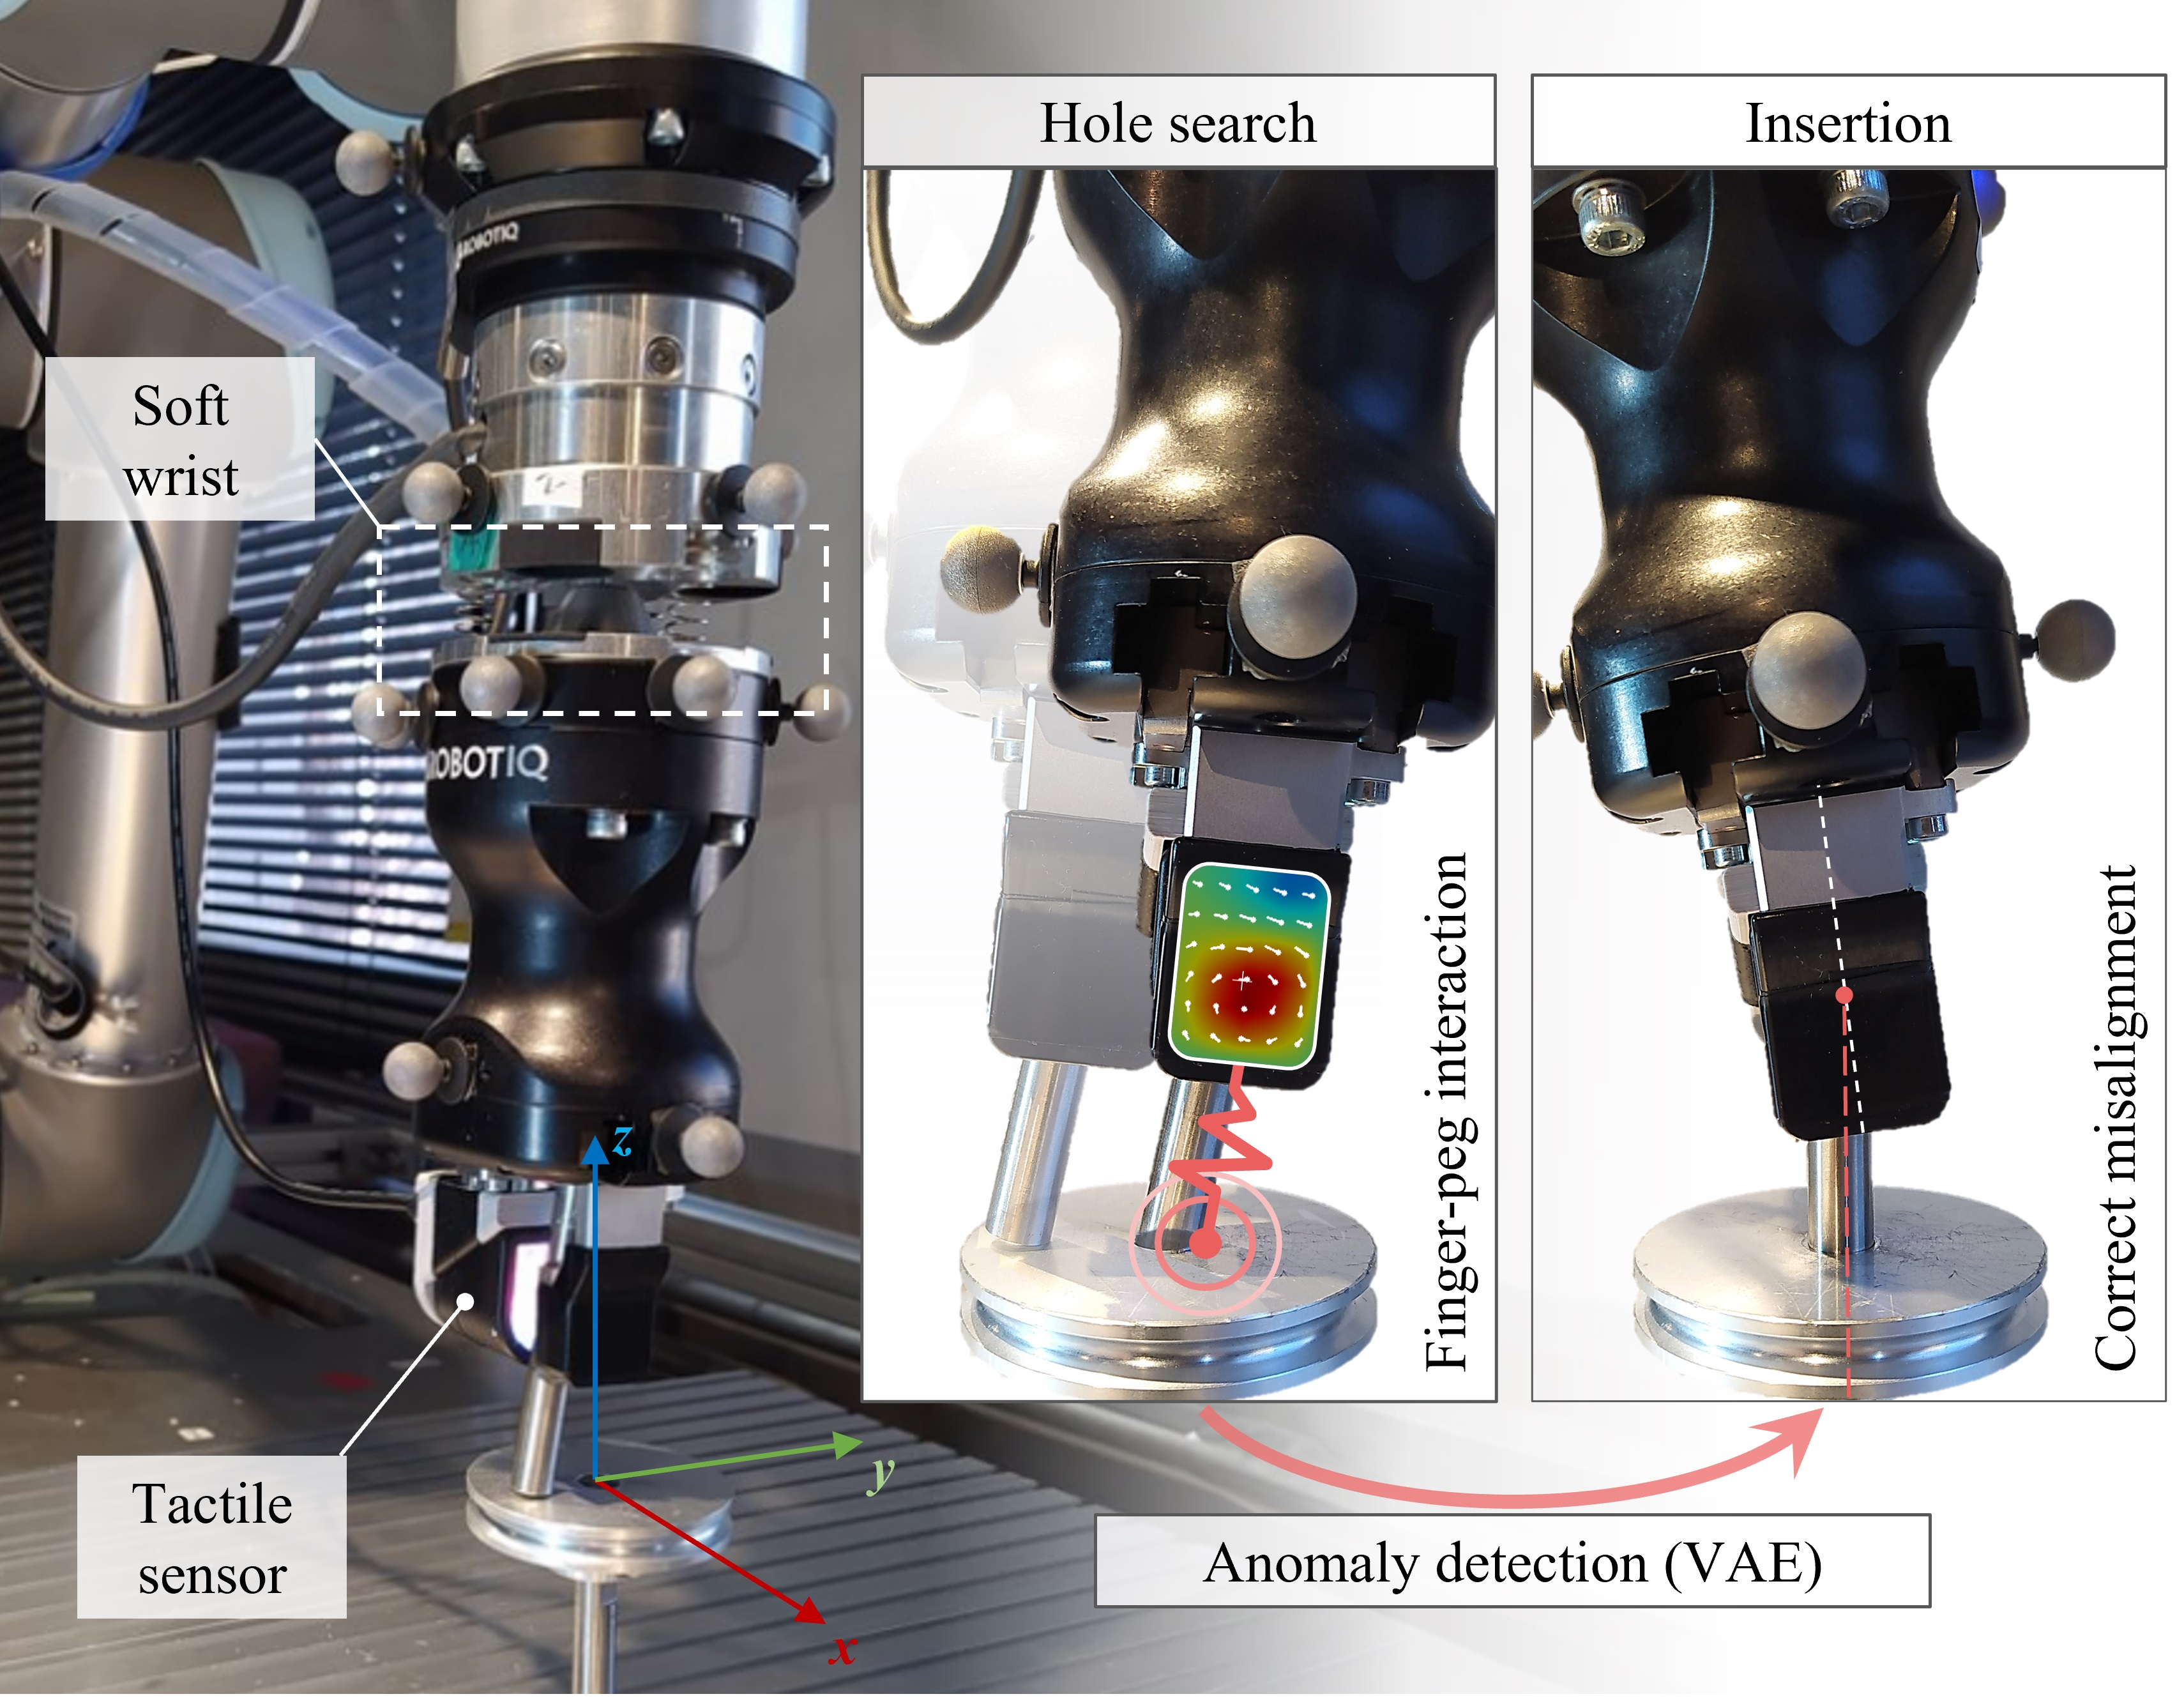
Robust and Resilient Soft Robotic Object Insertion with Compliance-Enabled Contact Formation and Failure Recovery
Soft Conical Universal Robotic Hand for Scooping Granular Media from Containers of Various Sizes
Worm Gear-based Adaptive Variable Elasticity for Decoupling Actuators from External Forces
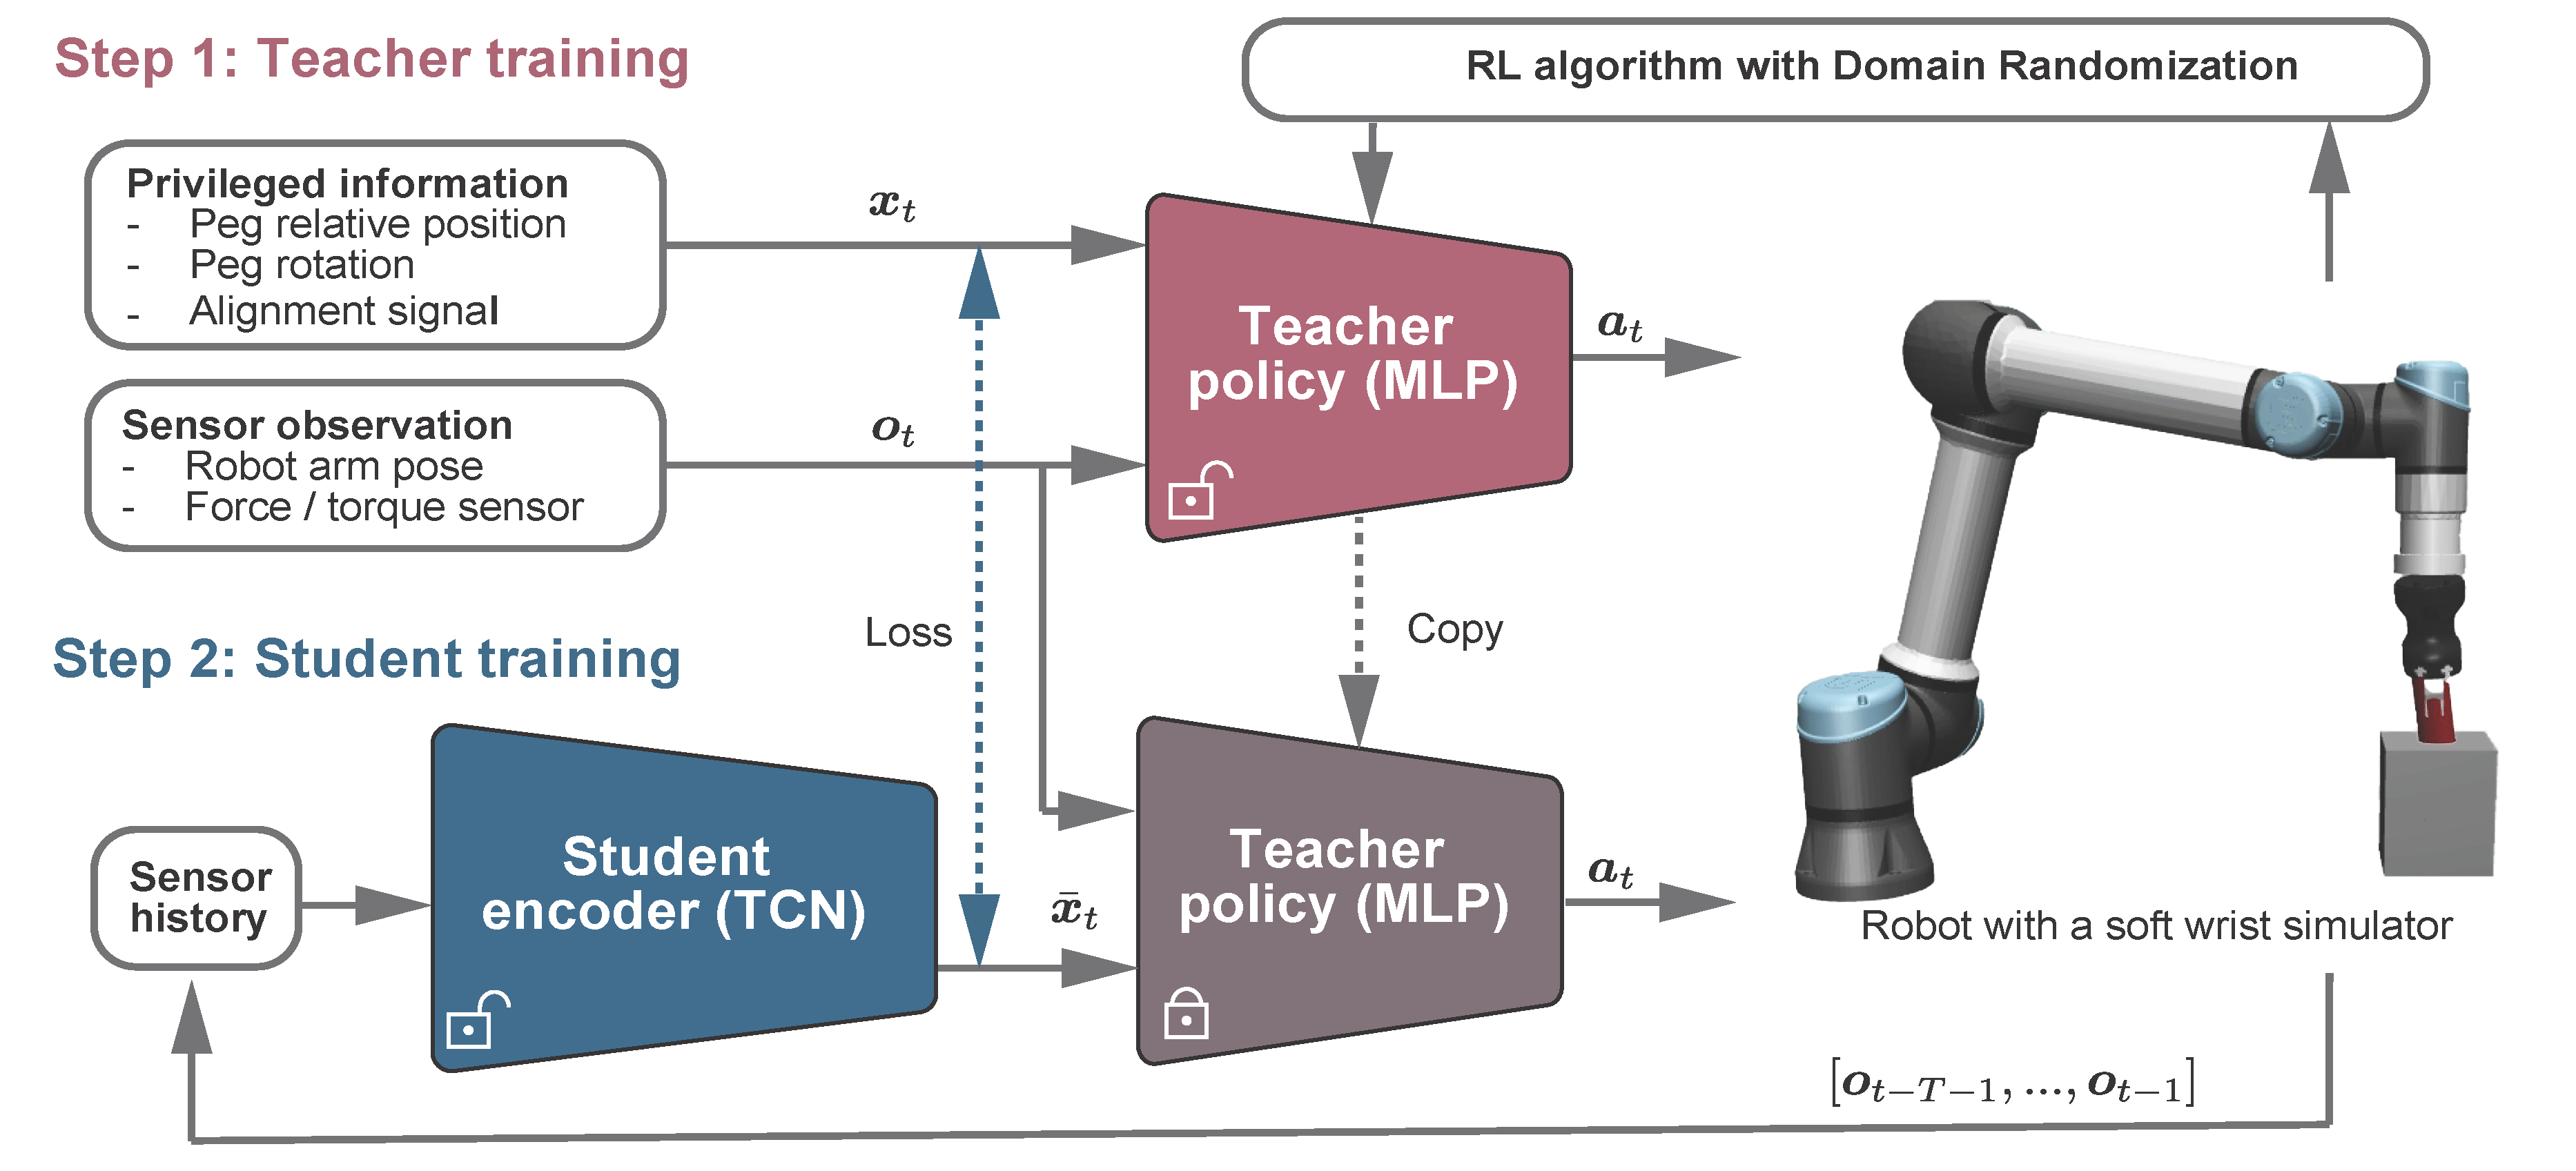
Robotic Object Insertion with a Soft Wrist through Sim-to-Real Privileged Training
Symmetry-aware Reinforcement Learning for Robotic Assembly under Partial Observability with a Soft Wrist
Learning Robotic Assembly by Leveraging Physical Softness and Tactile Sensing